Improved Board documentation
This commit is contained in:
 Sleeper85 committed
1 parent
1888ca31dc
commit
f3e77c327f
12 files changed
+550
-107
No files matched your search
@@ -69,10 +69,10 @@
|
||||
This project works with various `ESP32` variants and also with the `Raspberry Pi Pico (RP2040)`.
|
||||
Note that merging data from multiple BMS, balancers and shunts is resource-intensive, so I highly recommend a board based on the `ESP32-S3` with `PSRAM`.
|
||||
|
||||
| [LilyGo T-Connect](documents/README/Board_LilyGo_T-Connect.md) | [Waveshare RS485-CAN](documents/README/Board_Waveshare_ESP32-S3-RS485-CAN.md) | [M5Stack AtomS3R](https://docs.m5stack.com/en/core/AtomS3R) |
|
||||
| [LilyGo T-Connect](documents/README/Board_LilyGo_T-Connect.md) | [Waveshare RS485-CAN](documents/README/Board_Waveshare_ESP32-S3-RS485-CAN.md) | [M5Stack AtomS3R](documents/README/Board_M5Stack_AtomS3.md) |
|
||||
| --- | --- | --- |
|
||||
| - ESP32-S3<br>- 8MB PSRAM<br>- 3x RS485 port<br>- 1x CAN port<br>- 15x GPIOs | - ESP32-S3<br>- 8MB PSRAM<br>- 1x RS485 port<br>- 1x CAN port<br>- 1x SH1.0 connector<br>- 16x GPIOs | - ESP32-S3<br>- 8MB PSRAM<br>- 1x BASE port (**for adding RS485/CAN base**)<br>- 1x UNIT HY2.0 port (**for adding RS485/CAN unit**)<br>- 6x GPIOs |
|
||||
| <img src="images/MCU_ESP32-S3_LilyGo-T-Connect.jpg" width="300"> | <img src="images/MCU_ESP32-S3_WS-RS485-CAN.png" width="300"> | <img src="images/MCU_AtomS3R.png" width="300"> |
|
||||
| <img src="images/MCU_ESP32-S3_LilyGo-T-Connect_1.jpg" width="300"> | <img src="images/MCU_ESP32-S3_WS-RS485-CAN_2.png" width="300"> | <img src="images/MCU_AtomS3R.png" width="300"> |
|
||||
|
||||
### Single-node
|
||||
|
||||
|
||||
@@ -11,12 +11,6 @@
|
||||
> Using **DIP switch addresses 1 to 15** does not reliably guarantee that the **UART2 (RS485-2)** port protocol will be automatically configured to **001 - JK BMS RS485 Modbus V1.0**, which allows **YamBMS** to access BMS informations.
|
||||
> YamBMS users have confirmed that it is possible to resolve this issue by performing an [Erase History Data](BMS_JK-PB.md#erase-history-data) from the JK app on a smartphone.
|
||||
|
||||
|
||||
> The alternative solution is to use the **UART1 (RS485-1)** port configured with the **001 - JK BMS RS485 Modbus V1.0** protocol from the JK application.
|
||||
> Downgrading to **V19.10** does not guarantee to correct this problem, [please read this information before downgrading](BMS_JK-PB.md#downgrading-to-1910).
|
||||
|
||||
|
||||
|
||||
> [!IMPORTANT]
|
||||
> The most important thing for proper functioning of YamBMS is that **the voltage of your BMS is well calibrated**.
|
||||
> YamBMS logic is based on the `min_cell_voltage` and `max_cell_voltage` voltages of your BMS.
|
||||
|
||||
+10
-6
@@ -9,17 +9,21 @@
|
||||
> [!IMPORTANT]
|
||||
> BMS monitoring with `UART` or `RS485` is recommended.
|
||||
|
||||
## Number of BMS supported
|
||||
## BMS Support Capacity
|
||||
|
||||
* 2x BMS with `Bluetooth` (BLE stack consumes significant amount of RAM on device and can cause crash and reboot)
|
||||
* 3x `JK-B` BMS with `UART/RS485`
|
||||
* several `JK-PB` BMS with `RS485` (already tested with 7 BMS)
|
||||
Based on hardware limitations and testing, this board supports:
|
||||
|
||||
Note: these are theoretical limits, not all combinations have been tested.
|
||||
| Communication Method | Maximum BMS | Notes |
|
||||
|----------------------|-------------|-------|
|
||||
| **RS485** | Multiple BMS | Best option for monitoring many BMS units |
|
||||
| **UART** | 3× BMS | Must be connected to the GPIOs header |
|
||||
| **Bluetooth (BLE)** | 3× BMS (ESP32-S3) | BLE stack consumes significant RAM, may cause crashes/reboots |
|
||||
|
||||
**Note:** These are theoretical limits. Not all combinations have been tested.
|
||||
|
||||
## UART/IO Expander
|
||||
|
||||
It would be possible to add one or more [WK2168 4x UART expander](https://esphome.io/components/weikai.html) to increase the number of BMS monitored with `UART`.
|
||||
It would be possible to add one or more [WK2168 4x UART expander](https://esphome.io/components/weikai.html) to increase the number of `UART` port.
|
||||
|
||||
## Build your own PCB
|
||||
|
||||
@@ -20,7 +20,8 @@ The LilyGo T-Connect is a multi-functional development board based on the ESP32-
|
||||
- Rich Interfaces: Integrated APA102 LED driver, QWIIC expansion interface
|
||||
- Industrial Design: Wide voltage input (7V-12V DC), 4 positioning holes for easy installation
|
||||
|
||||

|
||||
<img src="../..//images/MCU_ESP32-S3_LilyGo-T-Connect_1.jpg" width="400">
|
||||
<img src="../..//images/MCU_ESP32-S3_LilyGo-T-Connect_2.jpg" width="400">
|
||||
|
||||
## Board Specifications
|
||||
|
||||
@@ -45,6 +46,22 @@ The T-Connect is available as a single version with the following specifications
|
||||
|
||||
**Note:** The T-Connect supports switching configuration between CAN and RS485 modules through onboard jumpers, allowing maximum flexibility with up to 3 RS485 ports + 1 CAN port simultaneously.
|
||||
|
||||
## BMS Support Capacity
|
||||
|
||||
Based on hardware limitations and testing, this board supports:
|
||||
|
||||
| Communication Method | Maximum BMS | Notes |
|
||||
|----------------------|-------------|-------|
|
||||
| **RS485** | Multiple BMS | Best option for monitoring many BMS units |
|
||||
| **UART** | 3× BMS | Must be connected to the GPIOs header |
|
||||
| **Bluetooth (BLE)** | 3× BMS | BLE stack consumes significant RAM, may cause crashes/reboots |
|
||||
|
||||
**Note:** These are theoretical limits. Not all combinations have been tested.
|
||||
|
||||
## UART/IO Expander
|
||||
|
||||
It would be possible to add one or more [WK2168 4x UART expander](https://esphome.io/components/weikai.html) to increase the number of `UART` port.
|
||||
|
||||
## Power Supply
|
||||
|
||||
The LilyGo T-Connect board can be powered using two methods:
|
||||
@@ -105,12 +122,12 @@ The CAN bus port is positioned at location **No.4** (see photo at the beginning
|
||||
|
||||
To connect an RS485 device to any of the configured RS485 ports:
|
||||
|
||||
| RS485 Port | Terminal Block |
|
||||
| RS485 | Terminal Block |
|
||||
| --- | --- |
|
||||
| SG | Shield/Signal Ground (optional but recommended) |
|
||||
| L pin | RS485 A (Data+) |
|
||||
| H pin | RS485 B (Data-) |
|
||||
| DG | Data/Device Ground (optional but recommended) |
|
||||
| - | SG : Shield/Signal Ground (optional but recommended) |
|
||||
| A + | L (RS485 A, Data+ non-inverting) |
|
||||
| B - | H (RS485 B, Data- inverting) |
|
||||
| GND | DG : Data/Device Ground (optional but recommended) |
|
||||
|
||||
**Wiring Steps:**
|
||||
1. Ensure the port is configured for RS485 mode using the onboard jumpers
|
||||
@@ -142,19 +159,19 @@ To connect an RS485 device to any of the configured RS485 ports:
|
||||
|
||||
To connect a CAN bus device to the CAN port:
|
||||
|
||||
| CAN Port | Terminal Block |
|
||||
| CAN bus | Terminal Block |
|
||||
| --- | --- |
|
||||
| SG | Shield/Signal Ground (optional but recommended) |
|
||||
| L pin | CAN L (CAN Low) |
|
||||
| H pin | CAN H (CAN High) |
|
||||
| DG | Data/Device Ground (optional but recommended) |
|
||||
| - | SG : Shield/Signal Ground (optional but recommended) |
|
||||
| CAN L | L (CAN Low) |
|
||||
| CAN H | H (CAN High) |
|
||||
| GND | DG : Data/Device Ground (optional but recommended) |
|
||||
|
||||
**Wiring Steps:**
|
||||
1. Ensure the port is configured for CAN mode using the onboard jumpers
|
||||
2. Identify the CAN H and CAN L wires from your CAN device
|
||||
3. Connect the **CAN H wire** to the **H pin** of the CAN port
|
||||
4. Connect the **CAN L wire** to the **L pin** of the CAN port
|
||||
5. **Connect the ground wire** to the **DG pin** for common reference (highly recommended)
|
||||
5. **Connect the ground wire** to the **DG pin** for common reference (optional but recommended)
|
||||
6. If using **shielded cable**, connect the shield to the **SG pin** (recommended for noisy environments)
|
||||
|
||||
**Ground Connection Best Practices:**
|
||||
@@ -316,12 +333,12 @@ For a typical YamBMS setup with the LilyGo T-Connect board:
|
||||
### Waveshare ESP32-S3-RS485-CAN vs LilyGo T-Connect
|
||||
|
||||
| Feature | Waveshare | LilyGo T-Connect |
|
||||
| --- | --- | --- |
|
||||
| ------- | --------- | ---------------- |
|
||||
| RS485 Ports | 1 (isolated) | Up to 3 (isolated) |
|
||||
| CAN Ports | 1 (isolated) | 1 (isolated) |
|
||||
| Built-in Termination | ✅ Yes (120Ω jumper-selectable) | ❌ No (external resistors required) |
|
||||
| Power Isolation | ✅ Yes | Unknown |
|
||||
| Signal Isolation | ✅ Yes (RS485 & CAN) | Likely yes |
|
||||
| Power Isolation | ✅ Yes | ❌ No |
|
||||
| Signal Isolation | ✅ Yes (RS485 & CAN) | ✅ Yes (RS485 & CAN up to 2500V) |
|
||||
| Enclosure | ✅ DIN rail ABS case included | ❌ No enclosure |
|
||||
| Power Input | 7-36V DC or USB-C | 7-12V DC or USB-C |
|
||||
| LED Indicators | PWR, RS485 TX/RX, CAN | PWR, APA102 support |
|
||||
|
||||
@@ -0,0 +1,470 @@
|
||||
# YamBMS - M5Stack AtomS3
|
||||
|
||||
[](https://www.gnu.org/licenses/gpl-3.0)
|
||||
[](https://github.com/Sleeper85/esphome-yambms/releases/latest)
|
||||

|
||||

|
||||

|
||||
|
||||
> [!IMPORTANT]
|
||||
> **GPIO Limitation:** AtomS3 provides **very few GPIOs**. This solution works best for:
|
||||
> - **Supervising multiple RS485 BMS**
|
||||
> - Limited number of UART BMS (3 maximum)
|
||||
> - Applications where compact size is priority
|
||||
|
||||
## Overview
|
||||
|
||||
The M5Stack **AtomS3** combined with the **Atomic CAN Base** provides a compact and powerful solution for YamBMS applications. This combination offers CAN bus communication with isolation, a built-in display, and expandability through additional M5Stack units.
|
||||
|
||||
**Key Features:**
|
||||
- Compact design (24×24×13mm AtomS3 footprint)
|
||||
- ESP32-S3 with 8MB Flash
|
||||
- Built-in 0.85" IPS display (128×128 pixels)
|
||||
- Isolated CAN bus communication (up to 1Mbps)
|
||||
- 6-axis IMU (MPU6886)
|
||||
- Expandable with M5Stack Units (RS485, CAN, etc.)
|
||||
- Programmable button
|
||||
- Multiple development platforms supported
|
||||
|
||||
## Board Variants & Components
|
||||
|
||||
### AtomS3 Controllers
|
||||
|
||||
Choose one AtomS3 controller to clip onto the Atomic CAN Base:
|
||||
|
||||
| [AtomS3 Lite](https://docs.m5stack.com/en/core/AtomS3%20Lite) | [AtomS3](https://docs.m5stack.com/en/core/AtomS3) | [AtomS3R (8MB PSRAM)](https://docs.m5stack.com/en/core/AtomS3R) |
|
||||
| --- | --- | --- |
|
||||
| <img src="../../images/MCU_AtomS3_Lite.png" width="300"> | <img src="../../images/MCU_AtomS3.png" width="300"> | <img src="../../images/MCU_AtomS3R.png" width="300"> |
|
||||
|
||||
| Model | Flash | PSRAM | Display | IMU | Best For |
|
||||
|-------|-------|-------|---------|-----|----------|
|
||||
| **[AtomS3 Lite](https://docs.m5stack.com/en/core/AtomS3%20Lite)** (C124) | 8MB | No | 0.85" IPS | MPU6886 | Budget projects |
|
||||
| **[AtomS3](https://docs.m5stack.com/en/core/AtomS3)** (C123) | 8MB | No | 0.85" IPS | MPU6886 | Standard applications |
|
||||
| **[AtomS3R](https://docs.m5stack.com/en/core/AtomS3R)** (C126) | 8MB | **8MB** | 0.85" IPS | MPU6886 | **Recommended** (extra RAM) |
|
||||
|
||||
**Recommendation:** Choose **AtomS3R (C126)** if using Bluetooth BLE for BMS communication, as the extra 8MB PSRAM helps prevent crashes when the BLE stack consumes significant RAM.
|
||||
|
||||
### Base & Communication Units
|
||||
|
||||
| [Atomic CAN Base](https://docs.m5stack.com/en/atom/Atomic%20CAN%20Base) | [CAN Unit](https://docs.m5stack.com/en/unit/can) | [RS485 Unit](https://docs.m5stack.com/en/unit/iso485) |
|
||||
| --- | --- | --- |
|
||||
| <img src="../../images/CAN_Transceiver_M5Stack_Atomic_CAN_Base.png" width="300"> | <img src="../../images/CAN_Transceiver_M5Stack_CAN_Unit.png" width="300"> | <img src="../../images/RS485_Transceiver_M5stack_SKU-U094_RS485_Isolated_Unit.png" width="300"> |
|
||||
|
||||
| Component | Type | Features | Use Case |
|
||||
|-----------|------|----------|----------|
|
||||
| **[Atomic CAN Base](https://docs.m5stack.com/en/atom/Atomic%20CAN%20Base)** (A103) | CAN Base | Isolated CAN, up to 1Mbps, 110 nodes | **Recommended** for inverter |
|
||||
| **[CAN Unit](https://docs.m5stack.com/en/unit/can)** (U085) | HY2.0 Unit | Isolated CAN via Grove port | Alternative CAN solution |
|
||||
| **[RS485-ISO Unit](https://docs.m5stack.com/en/unit/iso485)** (U094) | HY2.0 Unit | Isolated RS485, up to 500kbps, 256 nodes | For RS485 BMS or multi-node |
|
||||
|
||||
## BMS Support Capacity
|
||||
|
||||
Based on hardware limitations and testing, this board supports:
|
||||
|
||||
| Communication Method | Maximum BMS | Notes |
|
||||
|----------------------|-------------|-------|
|
||||
| **RS485** | Multiple BMS | Best option for monitoring many BMS units |
|
||||
| **UART** | 3× BMS | The 2nd and 3rd UARTs must be connected on Atomic CAN Base GPIOs |
|
||||
| **Bluetooth (BLE)** | 3× BMS | BLE stack consumes significant RAM, may cause crashes/reboots |
|
||||
|
||||
**Note:** These are theoretical limits. Not all combinations have been tested. For large installations with many BMS units, consider boards with more GPIOs like the LilyGo T-Connect or Waveshare ESP32-S3-RS485-CAN.
|
||||
|
||||
## AtomS3 Specifications
|
||||
|
||||
### Hardware Specifications
|
||||
|
||||
| Specification | Details |
|
||||
|--------------|---------|
|
||||
| **Microcontroller** | ESP32-S3FN8 |
|
||||
| **Processor** | Xtensa 32-bit LX7 dual-core @ up to 240MHz |
|
||||
| **Flash** | 8MB |
|
||||
| **PSRAM** | None (AtomS3 Lite/AtomS3) / 8MB Octal SPI (AtomS3R) |
|
||||
| **Display** | 0.85" IPS LCD, 128×128 resolution |
|
||||
| **IMU** | MPU6886 (6-axis gyro + accel, I2C 0x68) |
|
||||
| **Button** | 1× Programmable button |
|
||||
| **Infrared** | IR transmitter built-in |
|
||||
| **USB** | USB Type-C (power + programming) |
|
||||
| **DC-DC** | SY8089 (5V to 3.3V) |
|
||||
| **Power Input** | 5V via USB Type-C |
|
||||
| **Operating Temp** | 0°C ~ 40°C |
|
||||
| **Dimensions** | 24.0 × 24.0 × 12.9mm |
|
||||
| **Weight** | 6.9g |
|
||||
|
||||
### GPIO Pinout
|
||||
|
||||
**Available GPIOs (Bottom Pins):**
|
||||
- **G5** / **G6** / **G7** / **G8** / **G38** / **G39**
|
||||
- Power: **5V**, **3.3V**, **GND**
|
||||
|
||||
**HY2.0-4P Expansion Port:**
|
||||
| Pin | Color | Function |
|
||||
|-----|-------|----------|
|
||||
| 1 | Black | GND |
|
||||
| 2 | Red | 5V |
|
||||
| 3 | Yellow | G2 |
|
||||
| 4 | White | G1 |
|
||||
|
||||
**Internal Connections:**
|
||||
|
||||
| Peripheral | GPIO Pins | Notes |
|
||||
|-----------|-----------|-------|
|
||||
| **LCD Display** | MOSI: G21, SCK: G17, CS: G15, RS: G33, RST: G34, BL: G16 | SPI interface |
|
||||
| **MPU6886 (IMU)** | SDA: G38, SCL: G39 | I2C address 0x68 |
|
||||
| **IR Transmitter** | Built-in | For infrared control |
|
||||
|
||||
## Atomic CAN Base Specifications
|
||||
|
||||
### Hardware Specifications
|
||||
|
||||
| Specification | Details |
|
||||
|--------------|---------|
|
||||
| **CAN Transceiver** | CA-IS3050G (isolated) |
|
||||
| **Maximum Rate** | 1 Mbps |
|
||||
| **Supported Nodes** | Up to 110 nodes |
|
||||
| **Loop Delay** | 150ns (low) |
|
||||
| **Common-mode Voltage** | -12V to +12V |
|
||||
| **Isolation** | Built-in isolated DC-DC |
|
||||
| **Protection** | Signal protection + electrical line protection |
|
||||
| **External Port** | VH3.96-4P terminal block |
|
||||
| **Operating Temp** | 0°C ~ 40°C |
|
||||
| **Dimensions** | 24 × 48 × 18mm |
|
||||
| **Weight** | 11.1g |
|
||||
|
||||
### Atomic CAN Base Pinout
|
||||
|
||||
The Atomic CAN Base connects to AtomS3 through the bottom pins:
|
||||
|
||||
| Pin | LEFT | RIGHT | Pin |
|
||||
|-----|------|-------|-----|
|
||||
| | | 1 | 3.3V |
|
||||
| | 2 | 3 | UART_TX (CAN_TX) |
|
||||
| | 4 | 5 | UART_RX (CAN_RX) |
|
||||
| 5V | 6 | 7 | |
|
||||
| GND | 8 | 9 | |
|
||||
|
||||
**CAN Terminal Block (VH3.96-4P):**
|
||||
- **CAN H** (CAN High)
|
||||
- **CAN L** (CAN Low)
|
||||
- **GND** (Ground)
|
||||
|
||||
**Note:** The exact UART pins used depend on configuration. Check the schematic for GPIO assignment.
|
||||
|
||||
## RS485-ISO Unit Specifications
|
||||
|
||||
If you need RS485 communication (e.g., for RS485 BMS, multi-node), add the **RS485-ISO Unit (U094)**:
|
||||
|
||||
| Specification | Details |
|
||||
|--------------|---------|
|
||||
| **Isolation Chip** | CA-IS3082W |
|
||||
| **Maximum Rate** | 500 kbps |
|
||||
| **Supported Nodes** | Up to 256 nodes |
|
||||
| **Isolation Voltage** | 1000V RMS |
|
||||
| **Protection** | Fail-safe, Overcurrent, Thermal shutdown, ±15kV ESD |
|
||||
| **Connection** | HY2.0-4P Grove cable to AtomS3 |
|
||||
| **Terminal** | VH-3.96 4P (A, B, GND, +V) |
|
||||
| **Dimensions** | 56.0 × 24.0 × 10.2mm |
|
||||
| **Weight** | 9.1g |
|
||||
|
||||
**RS485-ISO Unit Pinout:**
|
||||
|
||||
| HY2.0-4P | Black | Red | Yellow | White |
|
||||
|----------|-------|-----|--------|-------|
|
||||
| PORT.C | GND | 5V | UART_RX | UART_TX |
|
||||
|
||||
**Termination Resistor:** The RS485-ISO Unit includes a **120Ω termination resistor** (provided separately) that can be connected when the unit is at an endpoint of the RS485 bus.
|
||||
|
||||
## Wiring Instructions
|
||||
|
||||
### Connecting CAN Bus (Atomic CAN Base)
|
||||
|
||||
The Atomic CAN Base provides **isolated CAN communication** via a VH3.96-4P terminal block.
|
||||
|
||||
|
||||
| CAN bus | Terminal Block (VH3.96-4P) |
|
||||
|---------|----------------------------|
|
||||
| CAN H | H (CAN High) |
|
||||
| CAN L | L (CAN Low) |
|
||||
| GND | GND (optional) |
|
||||
|
||||
**Wiring Steps:**
|
||||
1. Clip the AtomS3 onto the Atomic CAN Base (ensure proper alignment)
|
||||
2. Identify CAN H and CAN L wires from your inverter or CAN device
|
||||
3. Connect **CAN H** to **H** (CAN H terminal)
|
||||
4. Connect **CAN L** to **L** (CAN L terminal)
|
||||
5. Connect **GND** to **GND** for common reference (optional)
|
||||
|
||||
**CAN Bus Best Practices:**
|
||||
- The Atomic CAN Base features **built-in isolation** for protection
|
||||
- CAN bus operates at up to **1 Mbps** data rate
|
||||
- Supports up to **110 nodes** on the bus
|
||||
- Use twisted pair cable (120Ω impedance recommended)
|
||||
- **Termination:** Add 120Ω resistors at both ends of the CAN bus
|
||||
- If the AtomS3 is at an endpoint, connect a termination resistor
|
||||
- Check if your inverter has built-in termination before adding external resistors
|
||||
|
||||
### Connecting RS485 (RS485-ISO Unit)
|
||||
|
||||
If using the RS485-ISO Unit for RS485 devices:
|
||||
|
||||
| RS485 | Terminal Block (VH3.96-4P) |
|
||||
|-------|-----------------------------|
|
||||
| A + | A (Data+ non-inverting) |
|
||||
| B - | B (Data- inverting) |
|
||||
| GND | GND (Ground reference) |
|
||||
|
||||
**Wiring Steps:**
|
||||
1. Connect the RS485-ISO Unit to the AtomS3 via the **HY2.0-4P Grove cable** (Yellow=RX, White=TX)
|
||||
2. Identify A and B wires from your RS485 device (often labeled D+/D- or A/B)
|
||||
3. Connect **RS485 A (D+)** to **Pin 1** (A terminal)
|
||||
4. Connect **RS485 B (D-)** to **Pin 2** (B terminal)
|
||||
5. Connect **GND** to **Pin 3** for common reference (recommended)
|
||||
|
||||
**RS485 Best Practices:**
|
||||
- The RS485-ISO Unit features **1000V isolation** for protection
|
||||
- RS485 operates at up to **500 kbps** data rate
|
||||
- Supports up to **256 nodes** on the bus
|
||||
- Use twisted pair cable for noise immunity
|
||||
- **Termination:** Connect the included **120Ω resistor** between A and B if the unit is at an endpoint
|
||||
- The unit includes **fail-safe protection** (outputs high if input is open or shorted)
|
||||
|
||||
## Power Supply
|
||||
|
||||
### AtomS3 Power Options
|
||||
|
||||
**USB Type-C Power:**
|
||||
- Connect a USB Type-C cable for **5V power**
|
||||
- Recommended for programming, debugging, and testing
|
||||
- Built-in **SY8089 DC-DC converter** steps down 5V to 3.3V for ESP32-S3
|
||||
- Typical power consumption: 150-300mA (idle to active WiFi)
|
||||
|
||||
**External 5V via HY2.0-4P Grove port:**
|
||||
- Useful when powering the entire assembly from an external 5V supply
|
||||
|
||||
## Programming & Development
|
||||
|
||||
### Entering Download Mode
|
||||
|
||||
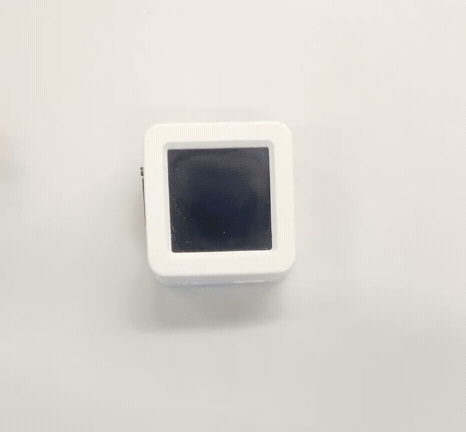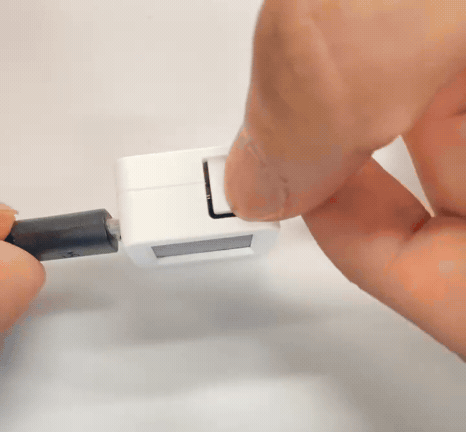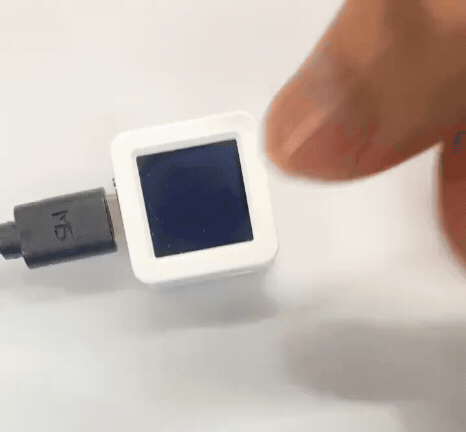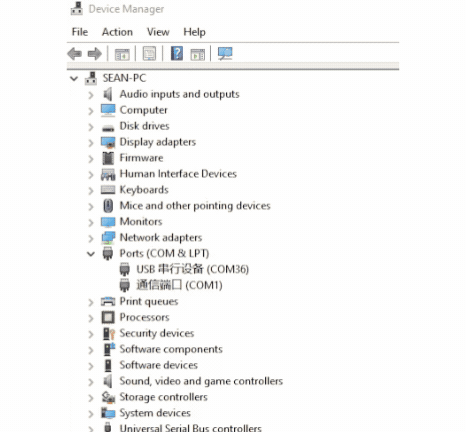
If you have trouble uploading firmware to the AtomS3:
|
||||
|
||||
**Manual Download Mode:**
|
||||
1. **Press and hold the RESET button** (about 2 seconds)
|
||||
2. Wait until the **internal green LED lights up**
|
||||
3. **Release the button**
|
||||
4. The device is now in download mode and ready for flashing
|
||||
|
||||
|
||||
|
||||
### LCD Backlight Control
|
||||
|
||||
**Important:** The PWM signal frequency for the LCD backlight driver should be **500Hz**. A frequency that is too high may cause abnormal brightness adjustment functionality.
|
||||
|
||||
**Backlight GPIO:** G16
|
||||
|
||||
## Display Features
|
||||
|
||||
### Screen Specifications
|
||||
|
||||
| Specification | Details |
|
||||
|--------------|---------|
|
||||
| **Size** | 0.85 inch IPS LCD |
|
||||
| **Resolution** | 128 × 128 pixels |
|
||||
| **Color Depth** | 65K colors |
|
||||
| **Driver IC** | GC9107 |
|
||||
| **Interface** | SPI |
|
||||
| **Backlight** | PWM controlled (GPIO16) |
|
||||
|
||||
### Display Control Parameters
|
||||
|
||||
The AtomS3's display can be controlled with the following parameters (useful for YamBMS display management):
|
||||
|
||||
**Backlight Settings:**
|
||||
- **Backlight control**: Manual brightness control (0-100%)
|
||||
- **Backlight max level**: Limit the maximum brightness in general
|
||||
- **Backlight auto-dim level**: Desired brightness when dimmed down (set to 0 to switch off screen completely)
|
||||
- **Backlight auto-dim time**: Time in minutes after which the screen will dim down (set to 0 to disable auto-dimming)
|
||||
|
||||
**Behavior Notes:**
|
||||
- Device restores last screen brightness after boot
|
||||
- Auto-dim timer does not start automatically - it gets initially started by pressing the screen button
|
||||
- Button press bumps brightness to 100% until the timer dims down again
|
||||
- This provides a lightweight solution without complex automation
|
||||
|
||||
## IMU (MPU6886)
|
||||
|
||||
The AtomS3 includes a built-in **MPU6886** 6-axis IMU:
|
||||
|
||||
| Sensor | Details |
|
||||
|--------|---------|
|
||||
| **Model** | MPU6886 |
|
||||
| **Interface** | I2C (address 0x68) |
|
||||
| **Pins** | SDA: GPIO38, SCL: GPIO39 |
|
||||
| **Features** | 3-axis gyroscope + 3-axis accelerometer |
|
||||
|
||||
**Use Cases for YamBMS:**
|
||||
- Orientation detection
|
||||
- Vibration monitoring
|
||||
- Installation angle verification
|
||||
- Advanced motion-based alerts (optional)
|
||||
|
||||
**Note:** The I2C pins on the back of the AtomS3 share the same bus with the MPU6886.
|
||||
|
||||
## Typical YamBMS Configuration
|
||||
|
||||
### Configuration 1: AtomS3 + Atomic CAN Base + RS485-ISO Unit (Full Setup)
|
||||
|
||||
**Best for:** Multiple RS485 BMS + inverter via CAN
|
||||
|
||||
**Components:**
|
||||
- AtomS3R (recommended)
|
||||
- Atomic CAN Base (A103)
|
||||
- RS485-ISO Unit (U094)
|
||||
|
||||
**Connections:**
|
||||
1. Clip AtomS3R onto Atomic CAN Base
|
||||
2. Connect inverter to CAN terminal (CAN H/L)
|
||||
3. Connect RS485-ISO Unit to AtomS3 via Grove cable (HY2.0-4P)
|
||||
4. Connect BMS RS485 bus to RS485 terminals (A/B)
|
||||
5. Power via USB Type-C
|
||||
6. Add termination resistors at bus endpoints
|
||||
|
||||
**GPIO Usage:**
|
||||
- CAN: Uses UART pins via Atomic CAN Base
|
||||
- RS485: Uses G1/G2 via HY2.0-4P Grove port
|
||||
- Display: Internal SPI (pre-configured)
|
||||
|
||||
### Configuration 2: BLE + CAN (Compact Wireless BMS)
|
||||
|
||||
**Best for:** 2-3 BLE devices + inverter via CAN
|
||||
|
||||
**Components:**
|
||||
- AtomS3R (8MB PSRAM required for stable BLE)
|
||||
- Atomic CAN Base (A103)
|
||||
|
||||
**Connections:**
|
||||
1. Clip AtomS3R onto Atomic CAN Base
|
||||
2. Connect inverter to CAN terminal
|
||||
3. Configure BMS via Bluetooth (up to 3× BMS maximum)
|
||||
4. Power via USB Type-C
|
||||
|
||||
**Limitations:**
|
||||
- BLE stack consumes significant RAM
|
||||
- May cause crashes/reboots with >2 BMS
|
||||
- No physical RS485 connection
|
||||
|
||||
## Troubleshooting
|
||||
|
||||
### AtomS3 Not Entering Download Mode
|
||||
- **Solution:** Press and hold RESET button (~2 seconds) until green LED lights up, then release
|
||||
- Try different USB cable (must support data transfer)
|
||||
- Check USB drivers are installed
|
||||
|
||||
### CAN Bus Communication Issues
|
||||
- Verify CAN H and CAN L are correctly connected (not swapped)
|
||||
- Check that CAN bus has **exactly two 120Ω termination resistors** (one at each end)
|
||||
- Verify CAN bus speed matches inverter (typically 500kbps)
|
||||
- Measure resistance between CAN H and CAN L (should be ~60Ω with proper termination)
|
||||
- Check isolation: the Atomic CAN Base has built-in isolation, but verify connections
|
||||
|
||||
### RS485 Communication Issues
|
||||
- Verify A and B wiring (try swapping if communication fails)
|
||||
- Check baud rate matches all RS485 devices
|
||||
- Ensure ground (GND) is connected for common reference
|
||||
- Add 120Ω termination resistor at RS485-ISO Unit if at bus endpoint
|
||||
- The RS485-ISO Unit has **fail-safe protection** - if input is open/shorted, receiver outputs high
|
||||
|
||||
### BLE Connection Issues (Bluetooth BMS)
|
||||
- AtomS3R (8MB PSRAM) strongly recommended for BLE
|
||||
- BLE stack consumes significant RAM - limit to 3 BMS maximum
|
||||
- May cause crashes/reboots if too many BLE connections
|
||||
- Consider switching to RS485 for multiple BMS units
|
||||
|
||||
### Display Issues
|
||||
- **Backlight frequency:** Ensure PWM frequency is **500Hz** (not higher)
|
||||
- **Brightness control:** Use manual control via button or software
|
||||
- **Auto-dim not working:** Timer requires manual activation by pressing button after boot
|
||||
|
||||
### GPIO Limitation Issues
|
||||
- **Problem:** Not enough GPIOs for all sensors/devices
|
||||
- **Solution:** Use I2C-based sensors (shares I2C bus with IMU)
|
||||
- **Alternative:** Consider boards with more GPIOs (LilyGo T-Connect, Waveshare ESP32-S3-RS485-CAN)
|
||||
|
||||
## Additional Resources
|
||||
|
||||
### Official M5Stack Documentation
|
||||
- [AtomS3 Official Docs](https://docs.m5stack.com/en/core/AtomS3)
|
||||
- [AtomS3 Lite Official Docs](https://docs.m5stack.com/en/core/AtomS3%20Lite)
|
||||
- [AtomS3R Official Docs](https://docs.m5stack.com/en/core/AtomS3R)
|
||||
- [Atomic CAN Base Official Docs](https://docs.m5stack.com/en/atom/Atomic%20CAN%20Base)
|
||||
- [RS485-ISO Unit Official Docs](https://docs.m5stack.com/en/unit/iso485)
|
||||
|
||||
### Schematics & Datasheets
|
||||
- [AtomS3 Schematic PDF](https://m5stack-doc.oss-cn-shenzhen.aliyuncs.com/472/Sch_M5_AtomS3_v1.0.pdf)
|
||||
- [AtomS3 IMU Schematic PDF](https://m5stack-doc.oss-cn-shenzhen.aliyuncs.com/472/Sch_AtomS3_IMU.pdf)
|
||||
- [ESP32-S3 Datasheet](https://m5stack-doc.oss-cn-shenzhen.aliyuncs.com/472/esp32-s3_datasheet_en.pdf)
|
||||
- [MPU6886 Datasheet](https://m5stack.oss-cn-shenzhen.aliyuncs.com/resource/docs/datasheet/core/MPU-6886-000193%2Bv1.1_GHIC_en.pdf)
|
||||
- [CA-IS3050G Datasheet](https://m5stack.oss-cn-shenzhen.aliyuncs.com/resource/docs/datasheet/unit/CA-IS3050G.pdf) (CAN transceiver)
|
||||
- [CA-IS3082W Datasheet](https://m5stack.oss-cn-shenzhen.aliyuncs.com/resource/docs/datasheet/unit/IS3082W.pdf) (RS485 transceiver)
|
||||
|
||||
### Software Libraries
|
||||
- [M5AtomS3 Arduino Library](https://github.com/m5stack/M5AtomS3)
|
||||
- [M5Unified Library](https://github.com/m5stack/M5Unified)
|
||||
- [AtomS3 Factory Firmware](https://github.com/m5stack/M5AtomS3-UserDemo)
|
||||
|
||||
### Where to Buy
|
||||
- [M5Stack Official Store](https://m5stack.com/)
|
||||
- [M5Stack AliExpress](https://m5stack.aliexpress.com/store/911661199)
|
||||
- [M5Stack Amazon](https://www.amazon.com/shops/m5stack)
|
||||
- [M5Stack Distributors](https://m5stack.com/distributor)
|
||||
|
||||
## Product Comparison
|
||||
|
||||
### AtomS3 vs Other YamBMS Boards
|
||||
|
||||
| Feature | AtomS3 + Atomic CAN | LilyGo T-Connect | Waveshare ESP32-S3-RS485-CAN |
|
||||
|---------|---------------------|------------------|------------------------------|
|
||||
| **Size** | Very compact (24×24mm) | Medium (94×83mm) | Medium with DIN rail case |
|
||||
| **Display** | ✅ 0.85" IPS (128×128) | ❌ No | ❌ No |
|
||||
| **RS485 Ports** | 1 (via Unit) | Up to 3 | 1 (isolated) |
|
||||
| **CAN Ports** | 1 (isolated) | 1 | 1 (isolated) |
|
||||
| **Isolation** | ✅ Yes (CAN + RS485 Unit) | ✅ Yes (both) | ✅ Yes (both) |
|
||||
| **Termination** | External | External | ✅ 120Ω jumper-selectable |
|
||||
| **GPIOs** | ⚠️ Very limited | Moderate | Moderate |
|
||||
| **PSRAM** | Optional (AtomS3R: 8MB) | 8MB | 8MB |
|
||||
| **Best For** | Compact installations, display needed, RS485 BMS | Multiple RS485 ports | Industrial, built-in termination |
|
||||
| **Price** | Moderate (modular) | Moderate | Moderate |
|
||||
|
||||
**When to Choose AtomS3:**
|
||||
- ✅ Compact size is critical
|
||||
- ✅ Built-in display desired
|
||||
- ✅ Modular expansion preferred
|
||||
- ✅ BMS via RS485 (multiple units)
|
||||
- ❌ Need many GPIOs
|
||||
- ❌ Need multiple RS485 ports simultaneously
|
||||
|
||||
## FAQ
|
||||
|
||||
**Q: Which AtomS3 variant should I choose?**
|
||||
A: For YamBMS, we recommend **AtomS3R (C126)** with 8MB PSRAM if using Bluetooth BLE, as it provides extra RAM to prevent crashes. For RS485-only applications, AtomS3 or AtomS3 Lite is sufficient.
|
||||
|
||||
**Q: Can I use multiple RS485 and CAN simultaneously?**
|
||||
A: Yes, but with limitations. AtomS3 has very few GPIOs. You can use Atomic CAN Base (CAN) + RS485-ISO Unit (RS485) simultaneously, but additional expansion is limited.
|
||||
|
||||
**Q: How many BMS can I monitor via UART?**
|
||||
A: Maximum 3× BMS via UART. The 2nd and 3rd UARTs requires soldering connections on the Atomic CAN Base.
|
||||
|
||||
**Q: Does the Atomic CAN Base require external termination resistors?**
|
||||
A: The Atomic CAN Base does not have built-in switchable termination. You must add external 120Ω resistors at both ends of the CAN bus.
|
||||
|
||||
**Q: Why does my BLE connection crash after adding the 3rd BMS?**
|
||||
A: The BLE stack consumes significant RAM. Use AtomS3R (8MB PSRAM) and limit to 3 BMS maximum.
|
||||
|
||||
**Q: Can I power the AtomS3 from the CAN bus?**
|
||||
A: No, you should power the AtomS3 via USB Type-C (5V). The CAN bus voltage is not suitable for directly powering the device.
|
||||
|
||||
**Q: How do I control the screen backlight?**
|
||||
A: Use PWM on GPIO16 at 500Hz frequency. Brightness can be controlled manually, and auto-dim requires button activation to start the timer.
|
||||
|
||||
---
|
||||
|
||||
**License:** This documentation is part of the YamBMS project and follows the same GPLv3 license.
|
||||
|
||||
**Acknowledgments:** Based on official M5Stack documentation and community contributions.
|
||||
@@ -22,7 +22,8 @@ The Waveshare ESP32-S3-RS485-CAN is an industrial-grade WiFi wireless communicat
|
||||
- Wide voltage input range (7-36V DC)
|
||||
- DIN rail mountable protective enclosure
|
||||
|
||||

|
||||
<img src="../..//images/MCU_ESP32-S3_WS-RS485-CAN_1.png" width="400">
|
||||
<img src="../..//images/MCU_ESP32-S3_WS-RS485-CAN_2.png" width="400">
|
||||
|
||||
## Board Specifications
|
||||
|
||||
@@ -43,6 +44,22 @@ The Waveshare ESP32-S3-RS485-CAN is an industrial-grade WiFi wireless communicat
|
||||
| Enclosure | Rail-mounted ABS protective case |
|
||||
| Programming | USB Type-C (firmware download & debugging) |
|
||||
|
||||
## BMS Support Capacity
|
||||
|
||||
Based on hardware limitations and testing, this board supports:
|
||||
|
||||
| Communication Method | Maximum BMS | Notes |
|
||||
|----------------------|-------------|-------|
|
||||
| **RS485** | Multiple BMS | Best option for monitoring many BMS units |
|
||||
| **UART** | 3× BMS | Must be connected to the GPIOs header |
|
||||
| **Bluetooth (BLE)** | 3× BMS | BLE stack consumes significant RAM, may cause crashes/reboots |
|
||||
|
||||
**Note:** These are theoretical limits. Not all combinations have been tested.
|
||||
|
||||
## UART/IO Expander
|
||||
|
||||
It would be possible to add one or more [WK2168 4x UART expander](https://esphome.io/components/weikai.html) to increase the number of `UART` port.
|
||||
|
||||
## Power Supply
|
||||
|
||||
The Waveshare ESP32-S3-RS485-CAN can be powered using two methods:
|
||||
@@ -116,14 +133,13 @@ To connect an RS485 device to the RS485 port:
|
||||
|
||||
| RS485 | Terminal Block |
|
||||
| --- | --- |
|
||||
| A (or +) | RS485 A / Data+ (non-inverting) |
|
||||
| B (or -) | RS485 B / Data- (inverting) |
|
||||
|
||||
| A + | RS485 A+ (Data+ non-inverting) |
|
||||
| B - | RS485 B- (Data- inverting) |
|
||||
|
||||
**Wiring Steps:**
|
||||
1. Identify the A and B wires from your RS485 device (may be labeled as D+/D-, A/B, or +/-)
|
||||
2. Connect the **A wire (D+ / Data+)** to the **A terminal**
|
||||
3. Connect the **B wire (D- / Data-)** to the **B terminal**
|
||||
2. Connect the **A wire (D+ / Data+)** to the **A+ terminal**
|
||||
3. Connect the **B wire (D- / Data-)** to the **B- terminal**
|
||||
4. Connect the **ground wire** to the **GND terminal** for common reference
|
||||
|
||||
**RS485 Best Practices:**
|
||||
@@ -138,16 +154,16 @@ To connect an RS485 device to the RS485 port:
|
||||
|
||||
To connect a CAN device to the CAN port:
|
||||
|
||||
| CAN | Terminal Block |
|
||||
| CAN bus | Terminal Block |
|
||||
| --- | --- |
|
||||
| H (CANH) | CAN High |
|
||||
| L (CANL) | CAN Low |
|
||||
| CAN H | CAN H (CAN High) |
|
||||
| CAN L | CAN L (CAN Low) |
|
||||
|
||||
**Wiring Steps:**
|
||||
1. Identify the CAN H and CAN L wires from your CAN device
|
||||
2. Connect the **CAN H wire** to the **H (CANH) terminal**
|
||||
3. Connect the **CAN L wire** to the **L (CANL) terminal**
|
||||
4. Connect the **ground wire** to the **GND terminal** for common reference
|
||||
4. Connect the **ground wire** to the **GND terminal** for common reference (optional)
|
||||
|
||||
**CAN Bus Best Practices:**
|
||||
- **Always connect the ground (GND)** for proper common mode voltage reference
|
||||
@@ -346,12 +362,12 @@ Waveshare provides demo firmware with a web interface:
|
||||
### Waveshare ESP32-S3-RS485-CAN vs LilyGo T-Connect
|
||||
|
||||
| Feature | Waveshare | LilyGo T-Connect |
|
||||
| --- | --- | --- |
|
||||
| ------- | --------- | ---------------- |
|
||||
| RS485 Ports | 1 (isolated) | Up to 3 (isolated) |
|
||||
| CAN Ports | 1 (isolated) | 1 (isolated) |
|
||||
| Built-in Termination | ✅ Yes (120Ω jumper-selectable) | ❌ No (external resistors required) |
|
||||
| Power Isolation | ✅ Yes | Unknown |
|
||||
| Signal Isolation | ✅ Yes (RS485 & CAN) | Likely yes |
|
||||
| Power Isolation | ✅ Yes | ❌ No |
|
||||
| Signal Isolation | ✅ Yes (RS485 & CAN) | ✅ Yes (RS485 & CAN up to 2500V) |
|
||||
| Enclosure | ✅ DIN rail ABS case included | ❌ No enclosure |
|
||||
| Power Input | 7-36V DC or USB-C | 7-12V DC or USB-C |
|
||||
| LED Indicators | PWR, RS485 TX/RX, CAN | PWR, APA102 support |
|
||||
|
||||
@@ -11,6 +11,7 @@
|
||||
* `JK` BMS (BLE / UART / RS485)
|
||||
* `JBD` BMS (BLE / UART)
|
||||
* `Seplos V1 V2 V3` BMS (RS485)
|
||||
* `PACE` BMS (RS485)
|
||||
* `BASEN` BMS (RS485)
|
||||
* `DEYE` BMS (CAN)
|
||||
|
||||
@@ -35,21 +36,18 @@
|
||||
|
||||
## Supported ESP32
|
||||
|
||||
**Recommended: AtomS3 or ESP32-S3**
|
||||
This project works with various `ESP32` variants and also with the `Raspberry Pi Pico (RP2040)`.
|
||||
Note that merging data from multiple BMS, balancers and shunts is resource-intensive, so I highly recommend a board based on the `ESP32-S3` with `PSRAM`.
|
||||
|
||||
* [M5Stack AtomS3 dedicated documentation](Supported_devices_M5Stack_AtomS3.md)
|
||||
* [PVbrain2 with ESP32-S3](https://github.com/SeByDocKy/pvbrain2) (up to 11 BMS monitored with `UART`)
|
||||
* [Build your own PCB with ESP32 or ESP32-S3](Supported_devices_Build_your_own_PCB.md)
|
||||
|
||||
| [AtomS3 Lite](https://docs.m5stack.com/en/core/AtomS3%20Lite) | [AtomS3](https://docs.m5stack.com/en/core/AtomS3) | [AtomS3R (8MB PSRAM)](https://docs.m5stack.com/en/core/AtomS3R) |
|
||||
| [AtomS3 Lite](Board_M5Stack_AtomS3.md) | [AtomS3](Board_M5Stack_AtomS3.md) | [AtomS3R (8MB PSRAM)](Board_M5Stack_AtomS3.md) |
|
||||
| --- | --- | --- |
|
||||
| <img src="../../images/MCU_AtomS3_Lite.png" width="300"> | <img src="../../images/MCU_AtomS3.png" width="300"> | <img src="../../images/MCU_AtomS3R.png" width="300"> |
|
||||
|
||||
| [LilyGo T-CAN485 (ESP32)](https://github.com/Xinyuan-LilyGO/T-CAN485) | [LilyGo T-Connect (ESP32-S3)](https://github.com/Xinyuan-LilyGO/T-Connect) | [Waveshare ESP32-S3-RS485-CAN](https://www.waveshare.com/esp32-s3-rs485-can.htm) |
|
||||
| [LilyGo T-CAN485 (ESP32)](https://github.com/Xinyuan-LilyGO/T-CAN485) | [LilyGo T-Connect (ESP32-S3)](Board_LilyGo_T-Connect.md) | [Waveshare ESP32-S3-RS485-CAN](Board_Waveshare_ESP32-S3-RS485-CAN.md) |
|
||||
| --- | --- | --- |
|
||||
| <img src="../../images/MCU_ESP32_LilyGo-T-CAN485.jpg" width="300"> | <img src="../../images/MCU_ESP32-S3_LilyGo-T-Connect.jpg" width="300"> | <img src="../../images/MCU_ESP32-S3_WS-RS485-CAN.png" width="300"> |
|
||||
| <img src="../../images/MCU_ESP32_LilyGo-T-CAN485.jpg" width="300"> | <img src="../../images/MCU_ESP32-S3_LilyGo-T-Connect_1.jpg" width="300"> | <img src="../../images/MCU_ESP32-S3_WS-RS485-CAN_1.png" width="300"> |
|
||||
|
||||
| [ESP32 DevKit-V1](https://a.aliexpress.com/_EG12CJ2) | [ESP32-S3 DevKitC-1](https://a.aliexpress.com/_EzFdrw3) | [ESP32-C3 ETH01-EVO](https://a.aliexpress.com/_Ey29fog) |
|
||||
| [ESP32 DevKit-V1](Board_Build_your_own_PCB.md) | [ESP32-S3 DevKitC-1](Board_Build_your_own_PCB.md) | [ESP32-C3 ETH01-EVO](https://a.aliexpress.com/_Ey29fog) |
|
||||
| --- | --- | --- |
|
||||
| <img src="../../images/MCU_ESP32-DevKit-V1.jpg" width="300"> | <img src="../../images/MCU_ESP32-S3-DevKitC-1.png" width="300"> | <img src="../../images/MCU_ESP32-C3_ETH01-EVO.png" width="300"> |
|
||||
|
||||
|
||||
@@ -1,56 +0,0 @@
|
||||
# YamBMS - M5Stack AtomS3, the Plug & Play solution (no welding)
|
||||
|
||||
[](https://www.gnu.org/licenses/gpl-3.0)
|
||||
[](https://github.com/Sleeper85/esphome-yambms/releases/latest)
|
||||

|
||||

|
||||

|
||||
|
||||
> [!IMPORTANT]
|
||||
> AtomS3 provides very few GPIOs.
|
||||
> This solution is not the best for supervising a large number of `JK-B BMS` via `UART` but it works very well for supervising a large number of `JK-PB BMS` via `RS485`.
|
||||
|
||||
> [!TIP]
|
||||
> If you have `JK-PB BMS` (inverter BMS) and want to monitor them via `RS485`, please read the [BMS JK-PB RS485](BMS_JK-PB_RS485_solution.md) dedicated topic.
|
||||
|
||||
## Number of BMS supported
|
||||
|
||||
* 3x BMS with `Bluetooth` (BLE stack consumes significant amount of RAM on device and can cause crash and reboot)
|
||||
* 2x `JK-B` BMS with `UART/RS485` (the second UART must be soldered on the Atomic CAN base on GPIOs G7 and G8)
|
||||
* several `JK-PB` BMS with `RS485` (already tested with 7 BMS)
|
||||
|
||||
Note: these are theoretical limits, not all combinations have been tested.
|
||||
|
||||
## List of M5Stack components that can be used depending on needs
|
||||
|
||||
> [!TIP]
|
||||
> Choose an `AtomS3` to clip onto the `Atomic CAN Base`.
|
||||
> Feel free to ask your question on the [DIY solar forum](https://diysolarforum.com/threads/yambms-jk-bms-can-with-new-cut-off-charging-logic-open-source.79325/) if you don't know what to choose.
|
||||
|
||||
- [AtomS3 Lite - SKU:C124](https://docs.m5stack.com/en/core/AtomS3%20Lite)
|
||||
- [AtomS3 - SKU:C123](https://docs.m5stack.com/en/core/AtomS3)
|
||||
- [AtomS3R - SKU:C126 (8MB PSRAM)](https://docs.m5stack.com/en/core/AtomS3R)
|
||||
- [Atomic CAN Base - SKU:A103 (recommended)](https://docs.m5stack.com/en/atom/Atomic%20CAN%20Base)
|
||||
- [CAN Unit - SKU:U085](https://docs.m5stack.com/en/unit/can)
|
||||
- [RS485 Unit - SKU:U094](https://docs.m5stack.com/en/unit/iso485)
|
||||
|
||||
| [AtomS3 Lite](https://docs.m5stack.com/en/core/AtomS3%20Lite) | [AtomS3](https://docs.m5stack.com/en/core/AtomS3) | [AtomS3R (8MB PSRAM)](https://docs.m5stack.com/en/core/AtomS3R) |
|
||||
| --- | --- | --- |
|
||||
| <img src="../../images/MCU_AtomS3_Lite.png" width="300"> | <img src="../../images/MCU_AtomS3.png" width="300"> | <img src="../../images/MCU_AtomS3R.png" width="300"> |
|
||||
|
||||
| [Atomic CAN Base (isolated)](https://docs.m5stack.com/en/atom/Atomic%20CAN%20Base) | [CAN Unit (isolated)](https://docs.m5stack.com/en/unit/can) | [RS485 Unit (isolated)](https://docs.m5stack.com/en/unit/iso485) |
|
||||
| --- | --- | --- |
|
||||
| <img src="../../images/CAN_Transceiver_M5Stack_Atomic_CAN_Base.png" width="300"> | <img src="../../images/CAN_Transceiver_M5Stack_CAN_Unit.png" width="300"> | <img src="../../images/RS485_Transceiver_M5stack_SKU-U094_RS485_Isolated_Unit.png" width="300"> |
|
||||
|
||||
## Note regarding the sensors managing the display backlight (ili9xxx platform)
|
||||
|
||||
* **Backlight control** : manual brightness control
|
||||
* **Backlight max level** : limit the max brightness in general
|
||||
* **Backlight Autodim level** : the desired brightness when dimmed down (set to 0 to switch off screen completely instead of dimming down)
|
||||
* **Backlight Autodim time in min** : time in minutes, after the screen will dim down (set to 0 to disable Auto dimming)
|
||||
|
||||
Device will restore last screen brightness after boot, but the timer script does not get start automatically.
|
||||
The auto dim timer gets initially started by pressing the screen button (which bumps up the brightness to 100% until the timer dims down then).
|
||||
|
||||
That seems to be the easiest and lightweight solution.
|
||||
But i guess some user could be confused and expect from the device to react immediately after changing some parameters.
|
||||

File renamed without changes.
|
Before Width: | Height: | Size: 408 KiB After Width: | Height: | Size: 408 KiB |

Binary file not shown.
|
After Width: | Height: | Size: 2.0 MiB |

Binary file not shown.
|
After Width: | Height: | Size: 189 KiB |

File renamed without changes.
|
Before Width: | Height: | Size: 120 KiB After Width: | Height: | Size: 120 KiB |
Reference in new issue
Block a user